The training and evaluation environments for robot brains.
LLMs became powerful because of the harness around them: data, environments, feedback, evaluation, and iteration. Robot brains need the same thing for the physical world.
“An evaluation harness is the infrastructure that runs evals end-to-end.”
— Anthropic, Demystifying evals for AI agents
OceanVeo provides that layer.
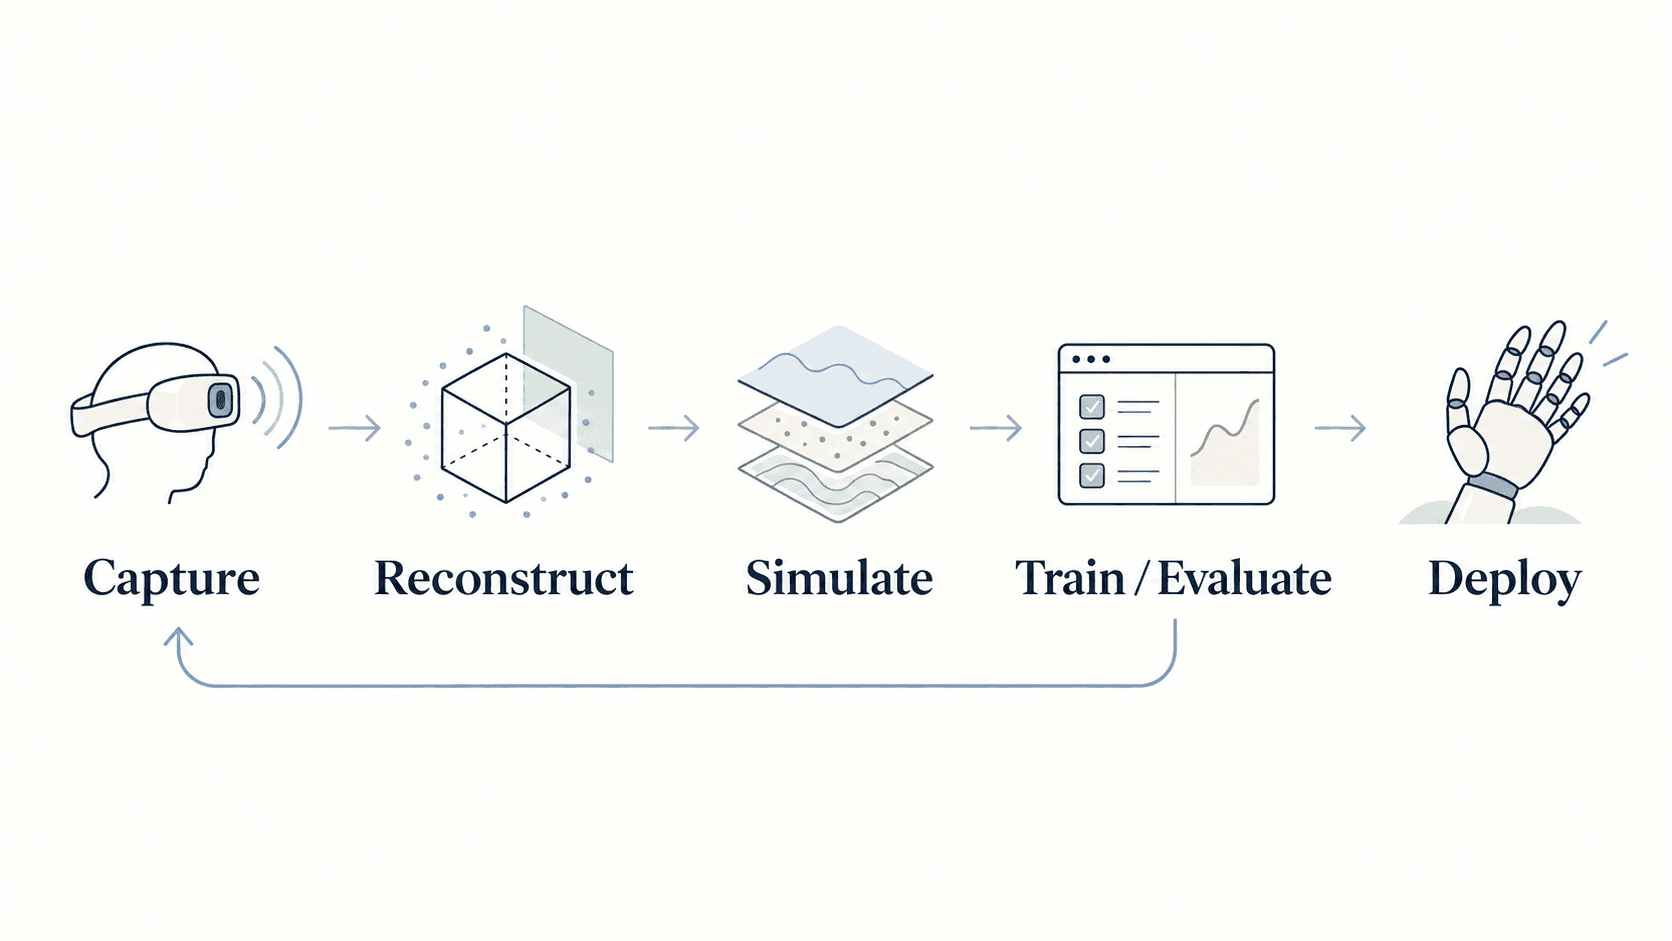
We turn real-world environments and human demonstrations into interactive worlds where robot policies can train, adapt, and be evaluated at scale.
We are researchers from Tesla Optimus & Autopilot, Meta, Stanford, Berkeley, and Caltech, with deep expertise across AI, robotics & data infra. Our work spans 10+ years of ML R&D, publications in Nature, CVPR, and ICRA, and 32K+ academic citations across multimodal foundation models, robotics, 3D vision, and rendering.
Today, we work with frontier labs and enterprises bridging the gap between robot intelligence and reliable real-world deployment.
If you’re building toward that future, let’s talk.
— Andrew, Sherelle & Alex